
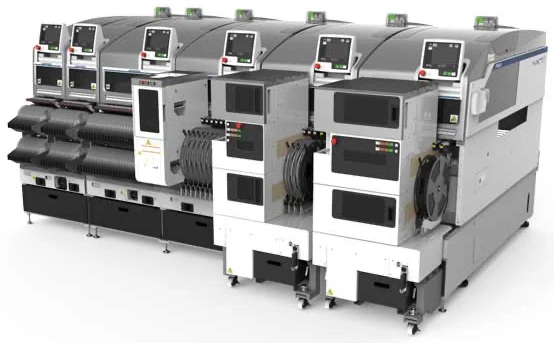
AI-Based SMT Line Pick & Place Robot Optimization
Narbeh Nahapetyan (ARC Smart Manufacturing Lab Coordinator)
Advanced Research Center
LAB: Smart Manufacturing
Research Topic | AI-Based SMT Line Pick and Place Robot Optimization | |
Submitted By: Narbeh Nahapetian | Submitted Date: January 23, 2025 | |
Purpose
The purpose of this research is to investigate on AI-driven strategies to optimize pick-and-place robot operations within Surface Mount Technology (SMT) production lines. By leveraging operational metrics and machine learning techniques, this research aims to reduce overall production cycle and switching time.
The Past and Current States
Historically, setting up P&P machines involved manual or semi-automated processes, relying on operator experience and extensive trial and error. While newer machines used tools offer basic optimization, they still demand significant human input, leading to longer setup times which cause production demands grow.
The Innovation
This research proposes a data driven, AI-based configuration by automatically analyzing product data files and machine constraints.
The Economic Effect
The system aims to reduce setup time, minimize operator intervention, and adapt quickly to changing production needs. Which will also lead to decrease in failing rates and increase of production capacity.
Research Justification
This research investigates how artificial intelligence can optimize the setup of P&P machines in Surface Mount Technology (SMT) production. By analyzing each product’s specific data file along with available machine-specific constraints, such as supported feeder banks, available feeders, number of gantries and supported heads, an AI-based framework will generate an optimized setup file specified to minimize machine overall cycle times and reduce manual configuration efforts. This research-based innovation is expected to improve P&P process time efficiency, enhance producing quality, and reduce setup time (setup can be done in parallel of production), making it a valuable for smart SMT production lines.
Project Scope
This project will use AI-driven methods to generate optimal setup for SMT P&P machines. The scope includes:
Data Analysis: This stage focuses on parsing product data files (like pick-and-place and BOM files) to extract critical parameters such as component types, placement location while considering specific machine constraints like available feeders, feeder banks, gantry and nozzles number and configurations.
AI Model Development: Based on the insights from the first stage, an AI-driven approach will be designed to generate optimized setup files, including feeder assignments and placement sequences that minimize cycle times and overall production time.
Challenges
Conducting thorough testing and simulations without disrupting active production lines can be difficult, especially when replicating real-world manufacturing conditions at a research scale. Reaching to a solution which can be adapted to different machine models will be an issue too. The limitation of P&P currently in hand can affect validation process too.
Project Deliverables
The project deliverables should reflect the research and planning aspects. Here's the deliverable items:
Feasibility Study: Analysis of current methods and identification of AI integration opportunities in scenarios of SMT P&P robot optimization.
Proof of Concept Plan: Such a system which will demonstrate how the research insights will be tested in a controlled environment, specifying the methodologies, overall performance and validation criteria.
Commercial Potential
We expect that the outcome of the research could be used for the developing of the following commercial product:
“AI Based SMT Line Mounting (Pick and Place) Machines Optimizer”