
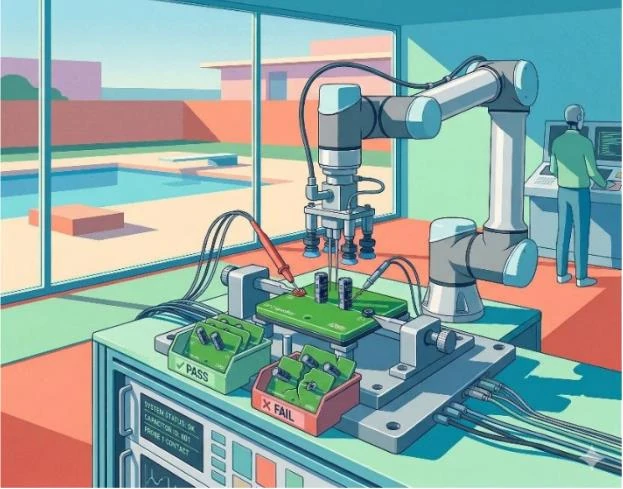
Robot-Assisted Testing and Sorting System
This is a joined project of the ARC (Smart Manufacturing & Robotics Lab) and Project Integration.
Purpose-Goals
The primary objective is to optimize the existing product testing process by replacing manual loading and sorting with an automated, robot-assisted system. This involves utilizing a robotic arm for precision handling, integrated via the SINUS software plugin.
The Past and Current States
The current process relies on manual insertion of the Device Under Test (DUT) into Automated Test Equipment (ATE), taking 5-10 seconds per unit, followed by manual sorting into Pass/Fail batches.
The Innovation
Automation via robotic arm for loading/unloading. A 'System Handshake' protocol between the robot and ATE enables autonomous testing cycles.
The Economic Effect
Increased throughput by eliminating manual idle time and human sorting errors. Reduced operational labor costs per unit tested.
Research Justification
The SINUS software used in the current setup already features a built-in plugin specifically designed for integrating external handlers and probers. This provides a direct, low-risk technical path for implementing the proposed automation.
Project Scope
Development of robotic path planning for loading/unloading, implementation of the ATE-Robot communication handshake, and the design of automated sorting trays.
Challenges
Key challenges include jigs design for DUT feeding, synchronization of the 'Ready for Testing' and 'Testing Finished' signals, and secure data payload transmission for sorting.
Project Deliverables
A functional automated testing station prototype featuring robotic arm and integrated sorting capability.
Next Steps
As a next step a machine vision feature should be added.
Commercial Potential
Develop a Universal Automated Module Testing and Sorting System for high-volume electronics manufacturing