
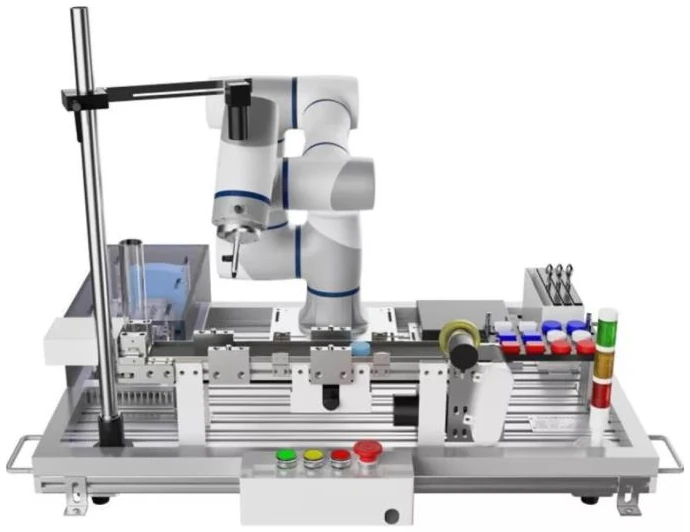
Universal Automation Stand for CR3 Cobot
This project is being done in ARC's Smart Manufacturing & Robotics Lab.
Purpose-Goals
To design and develop a universal stand for DOBOT CR3 paired with cried industrial controller and associated sensors to handle common automation tasks through image processing, assembly line simulation, and the operation and commissioning of grippers.
Study Abstract
This study focuses on the design and development of a universal automation stand using the DOBOT CR3 collaborative robot integrated with an industrial controller and associated sensors. The system is intended to support common industrial automation tasks, including image processing, assembly line simulation, and the operation and commissioning of robotic grippers. The project aims to provide a flexible and scalable platform for research, training, and practical automation applications while improving system integration, operational efficiency, and process adaptability in modern manufacturing environments.
Project Scope
Modular mechanical design and development of a complete automation stand assembly
Design and implementation of an indexing turntable for automated part handling
Integration of the DOBOT CR3 collaborative robot with a cRIO-based industrial control system, including motors, drivers, and sensors
Control system development using LabVIEW for automation and process control
3D CAD modelling and detailed mechanical design using SolidWorks
Rapid prototyping through 3D printing and preparation of parts for CNC machining
Industrial automation system development, including control logic, communication, and system integration
Machine vision integration for object detection, positioning, and automation tasks
Development, testing, and commissioning of robotic gripper systems for pick-and-place operations
Challenges
System Integration Complexity
Precision in Mechanical and Motion Design
Real-Time Control and Machine Vision Synchronization
Project Deliverables
Fully designed and assembled modular automation stand
Operational indexing turntable system for part positioning and handling
Integrated robotic system using the DOBOT CR3 with cRIO-based control architecture
Developed control software and user interface in LabVIEW
Complete 3D CAD design package created in SolidWorks
Prototype components produced through 3D printing and validated for functionality
CNC-ready mechanical part drawings and manufacturing files
Implemented industrial automation control logic and system communication framework
Machine vision system for object detection, tracking, and positioning
System integration and testing documentation, including performance validation results
Final technical report and user documentation for operation and maintenance
Commercial Potential
Training and education platform for robotics, automation, and machine vision
Low-cost industrial prototyping and testing cell for manufacturing workflows
Modular, customizable automation solution for small and medium-sized enterprises