
The ARC Journal
Issue 3/2026
Setting the pages…
Engineering Association
Issue3/2026

The ARCJournal

Yerevan, May 6, 2026

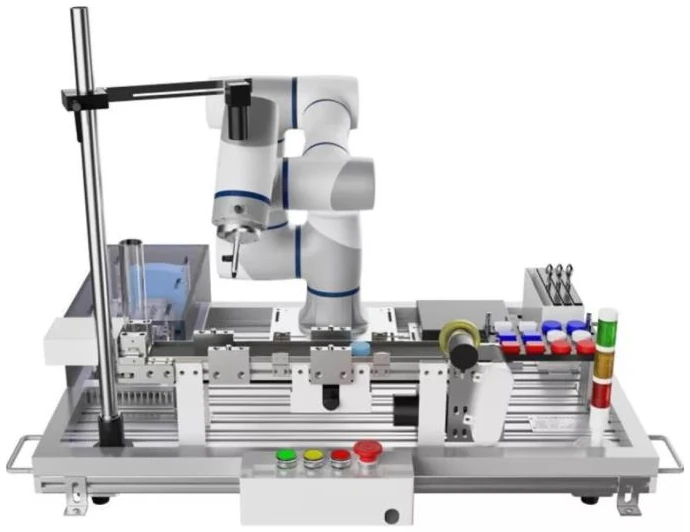
Example of such a stands
New ProjectsUniversal Automation Stand for CR3 Cobot
A Technology Research Publication

The ARC Journal

Issue 3/2026 · Yerevan, May 6, 2026

The Advanced Research Center (ARC)

The Advanced Research Center (ARC) was created at the Engineering City to conduct research in technologies, products, and applications of the future. It currently consists of five labs – Smart Manufacturing & Robotics Lab, Aerospace Lab, Semiconductor Lab, Automotive Lab, and Cybersecurity & Computetion Lab.

Published by the Engineering Association

The ARC JournalIssue 3/2026Published by the Engineering AssociationYerevan, May 6, 2026
End of issueThe ARC JournalIssue 3/2026Table of ContentsFront coverOriginal PDF

Table of Contents

New ProjectsUniversal Automation Stand for CR3 CobotPurpose-GoalsStudy AbstractProject ScopeChallengesProject DeliverablesCommercial PotentialVacum Gripper Design and DevelopmentPurpose-GoalsStudy AbstractProject ScopeChallengesProject DeliverablesCommercial Potential
New Projects

Universal Automation Stand for CR3 Cobot

English translation

This project is being done in ARC's Smart Manufacturing & Robotics Lab.

Purpose-Goals

To design and develop a universal stand for DOBOT CR3 paired with cried industrial controller and associated sensors to handle common automation tasks through image processing, assembly line simulation, and the operation and commissioning of grippers.

Figure 1. Example of such a stands

Study Abstract

This study focuses on the design and development of a universal automation stand using the DOBOT CR3 collaborative robot integrated with an industrial controller and associated sensors. The system is intended to support common industrial automation tasks, including image processing, assembly line simulation, and the operation and commissioning of robotic grippers. The project aims to provide a flexible and scalable platform for research, training, and practical automation applications while improving system integration, operational efficiency, and process adaptability in modern manufacturing environments.

Project Scope

  • Modular mechanical design and development of a complete automation stand assembly

  • Design and implementation of an indexing turntable for automated part handling

  • Integration of the DOBOT CR3 collaborative robot with a cRIO-based industrial control system, including motors, drivers, and sensors

  • Control system development using LabVIEW for automation and process control

  • 3D CAD modelling and detailed mechanical design using SolidWorks

  • Rapid prototyping through 3D printing and preparation of parts for CNC machining

  • Industrial automation system development, including control logic, communication, and system integration

  • Machine vision integration for object detection, positioning, and automation tasks

  • Development, testing, and commissioning of robotic gripper systems for pick-and-place operations

Challenges

  • System Integration Complexity

  • Precision in Mechanical and Motion Design

  • Real-Time Control and Machine Vision Synchronization

Project Deliverables

  • Fully designed and assembled modular automation stand

  • Operational indexing turntable system for part positioning and handling

  • Integrated robotic system using the DOBOT CR3 with cRIO-based control architecture

  • Developed control software and user interface in LabVIEW

  • Complete 3D CAD design package created in SolidWorks

  • Prototype components produced through 3D printing and validated for functionality

  • CNC-ready mechanical part drawings and manufacturing files

  • Implemented industrial automation control logic and system communication framework

  • Machine vision system for object detection, tracking, and positioning

  • System integration and testing documentation, including performance validation results

  • Final technical report and user documentation for operation and maintenance

Commercial Potential

  • Training and education platform for robotics, automation, and machine vision

  • Low-cost industrial prototyping and testing cell for manufacturing workflows

  • Modular, customizable automation solution for small and medium-sized enterprises

New Projects

Vacum Gripper Design and Development

English translation

This project is being done in ARC's Smart Manufacturing & Robotics Lab.

Purpose-Goals

Project to design and develop a compact electrical vacuum gripper that can work with collaborative robotic arms.

Figure 2. Example of all electric vacuum gripper

Study Abstract

This project focuses on the design and development of a compact electrical vacuum gripper compatible with collaborative robotic arms. The primary goal is to create a lightweight, energy-efficient, and reliable gripping solution capable of handling a variety of objects in automated industrial and laboratory environments. The study explores the integration of vacuum generation, electronic control systems, and mechanical design to ensure safe and precise operation alongside human workers. Emphasis is placed on improving portability, adaptability, and ease of integration with collaborative robots while maintaining stable gripping performance. The developed system aims to support modern automation applications by enhancing flexibility, safety, and operational efficiency in robotic handling tasks.

Project Scope

  • Conduct market research on existing all-electric vacuum grippers and develop a balanced architecture compatible with commonly used collaborative robotic arms.

  • Perform research and development of a compact electronic control circuit for the vacuum gripper system.

  • Design the complete mechanical structure of the compact vacuum gripper.

  • Develop a compatible communication interface supporting the Dobot communication port integrated within the robotic end effector.

  • Develop a software library for controlling and operating the gripper through Dobot Studio.

Challenges

  • Compatibility with Collaborative Robotic Arms

  • Compact Mechanical and Electronic Design

  • Software and Communication Integration

Project Deliverables

  • Market research and comparative analysis report on existing all-electric vacuum grippers.

  • System architecture design document for a compact vacuum gripper compatible with collaborative robotic arms.

  • Prototype of the compact electronic control circuit for the gripper system.

  • Complete mechanical design package, including 3D CAD models and technical drawings.

  • Integrated communication interface compatible with the Dobot end-effector communication port.

  • Functional software library for controlling the gripper through Dobot Studio.

  • Fully assembled and operational compact electrical vacuum gripper prototype.

  • Testing and validation report covering gripping performance, compatibility, reliability, and safety.

  • Final project documentation, including user guide and technical specifications.

Commercial Potential

The compact all-electric vacuum gripper has strong commercial potential in collaborative robotics and industrial automation due to its lightweight design, easy integration, reduced maintenance requirements, and compatibility with modern robotic arms such as Dobot systems.

© 2026 The Authors of the articles

All materials contained in The ARC Journal may be used with reference to the Authors.

For feedback on the Journal, its content, and its articles please send to info@engineeringcity.am.

To submit articles, please send to info@engineeringcity.am. Articles can be in any language.